[ C1 / WHO WE ARE ]
Twelve students. One rookie season. One machine.
We're Apex Robotics — FIRST® Tech Challenge Team 36674 from Tracy, California, competing in BIOBUZZ™ presented by RTX.
- Students
- 12
- Rookie year
- 2026
- Founder
- Anish P.
FIRST® Tech Challenge Team 36674 Tracy, CA BIOBUZZ™ 2026–27
[ C1 / WHO WE ARE ]
We're Apex Robotics — FIRST® Tech Challenge Team 36674 from Tracy, California, competing in BIOBUZZ™ presented by RTX.
[ C2 / APEX-R1 ]
APEX-R1 starts inside an 18-inch cube, drives on mecanum wheels and launches from a turret that keeps its aim while the chassis moves.
Source · Competition Manual TU04 · R102 · RobotConstants.java
[ C3 / DRIVE + ODOMETRY ]
Mecanum wheels strafe and turn at once. A goBILDA Pinpoint fuses two dead-wheel pods with an IMU at 1500 Hz, so the robot always knows its position and velocity — even when the HIVE moves.
[ C4 / INTAKE + SORTER ]
Rollers pull balls into the hopper, where a REV Color Sensor V3 tells POLLEN from NECTAR, sets the flywheel RPM for that ball and ejects the opponent's NECTAR — rule G408, a rule-compliance feature, not just an efficiency one.
[ C5 / TURRET + SOLVER ]
Odometry says where we are. Vision says where the HIVE is. The solver closes the loop: flight time falls out of the fixed 40° hood, the turret leads the moving shot, and the flywheel spins to the exact RPM.
Move over the field to aim · click or press F to fireTap the field beside the robot to aim and fire
[ C6 / THE SEASON ]
A HIVE TIP is worth ten CELL points — so we built for consistency: no shot fires until four gates agree.
Source · Competition Manual TU04 · 9.8 · Table 10-2
[ T / THE TEAM ]
Twelve students across CAD, code, build and outreach — founded by Anish Pattanaik in 2026.
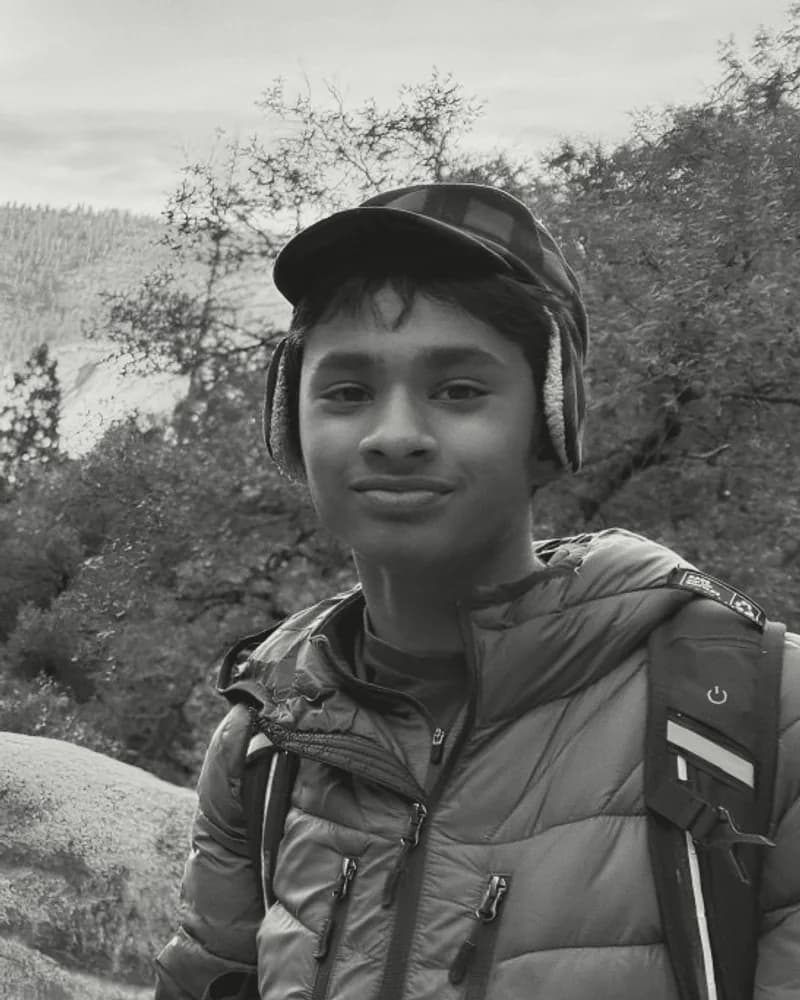
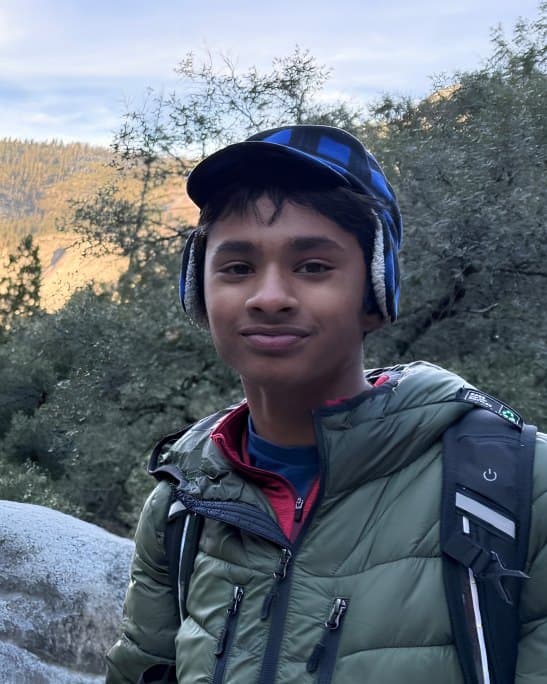 Anish PattanaikFounder & Team Captain
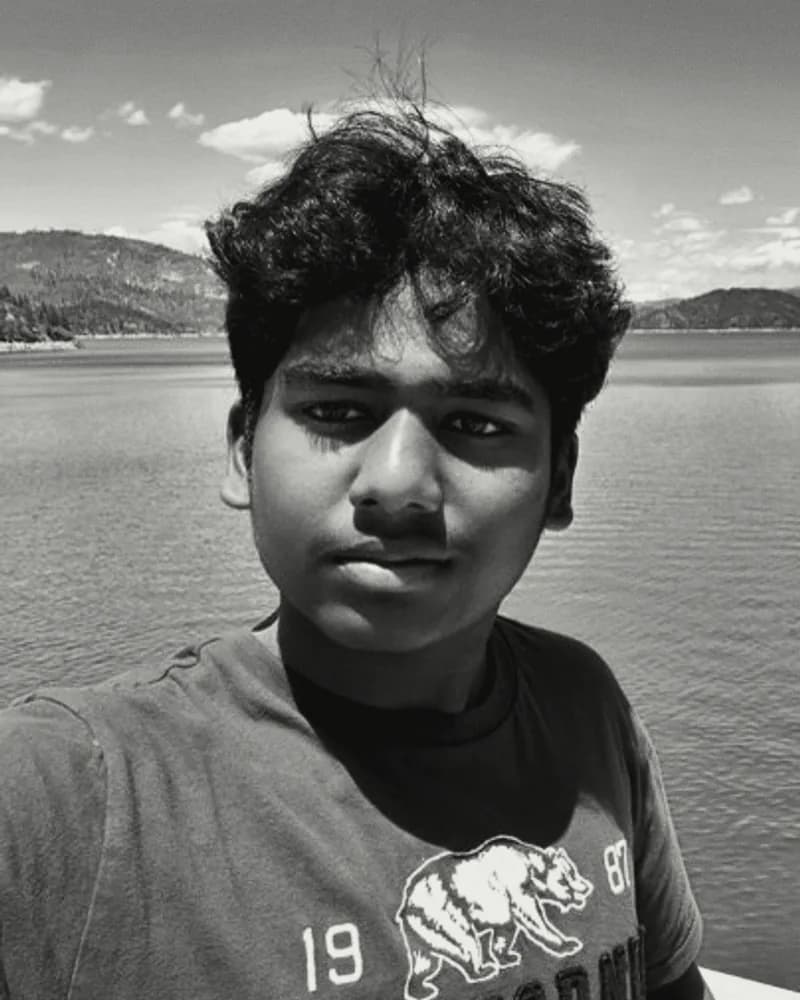
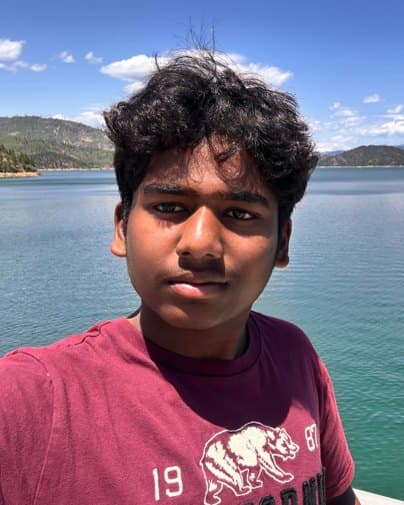 Abhinav AyyauCAD · Build
 Shubham PriyadarshiCAD · Code · Build · Socials
 Siddhant VengantiCAD · Build
 Agamveer SinghCode
5 of 12 portraits published · 7 pending
[ I / INDEX ]
07 SHEETS
Every page of this site is a sheet. Pick one.
[ S / SPONSORS ]
As a rookie team in our inaugural season, Team 36674 is building more than just a robot — we are building a foundation for STEM excellence in our community.
Typical rookie startup budget · $3,800–$5,500Source · Team 36674 sponsorship proposal